Projects 2026
Laminar
A camera-guided robot for liquid handling, built in a weekend by a team of four.
Winner, [MLH] Best Use of Tiger Data, Cal Hacks 13.0 (sponsor category)
What it does
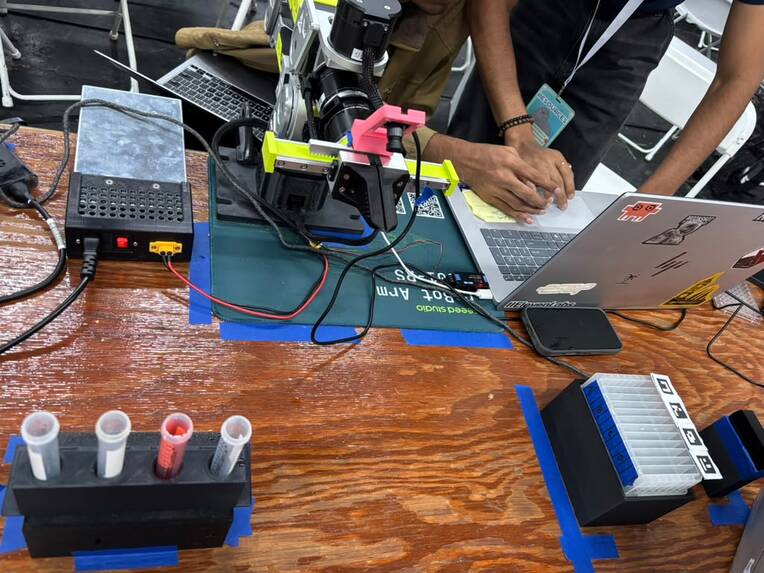
Laminar pairs a six-joint Seeed reBot B601-RS arm with a side camera that reads the liquid level in a tube. You describe a task in plain language. An AI planner drafts the steps, a deterministic validator checks them, and nothing moves until a named person approves the plan.
The dashboard streams each run live, and TigerData stores the telemetry: commanded and measured joint angles, tracking error, and every step the executor took.
My part
I wrote the software layer. Every piece of hardware sits behind an interface with a fake twin, so the whole job loop could be built and tested before the arm was connected. The executor runs each step as preconditions, then the skill, then a success check, and backs off to a safe pose if anything fails. Staged faults (a wrong tube, a slipped grasp, an overshot pour, a blocked camera) exercise those paths. A watchdog stops the arm on an emergency stop or after 250 ms without a heartbeat.
I also built the Claude agent and its four tools, the voice interface, telemetry, the dashboard and the integrations. Avery led the arm control and Amogh the vision.
What was real, and what was simulated
On the physical bench, the arm made a camera-controlled 3.4 mL pour. The Fetch.ai/ASI:One and Mana integrations ran against the simulated bench during the hackathon. Laminar is a weekend prototype: it hasn’t been validated for accuracy or safety in a real lab.
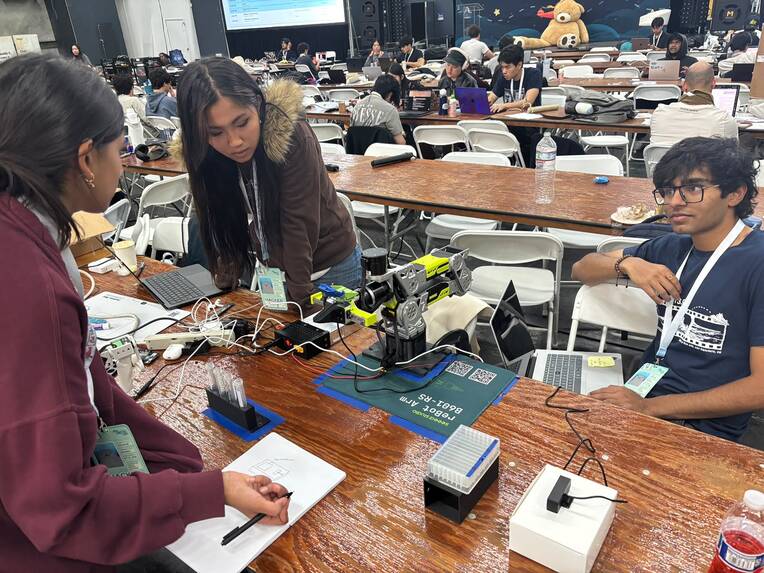
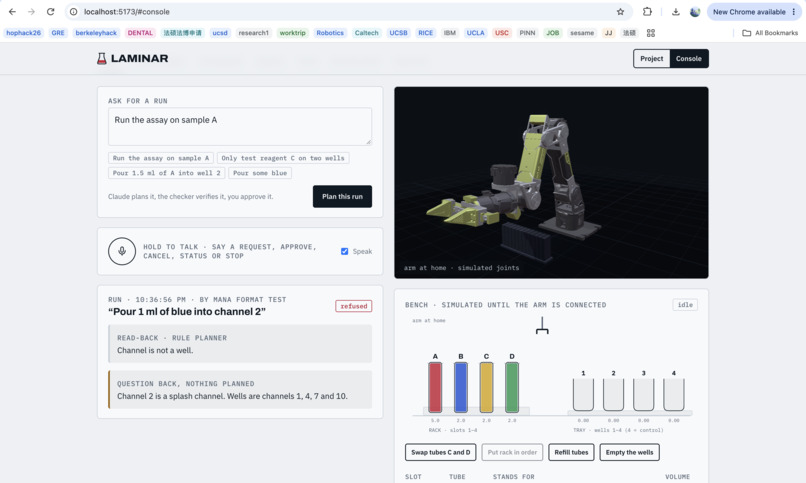
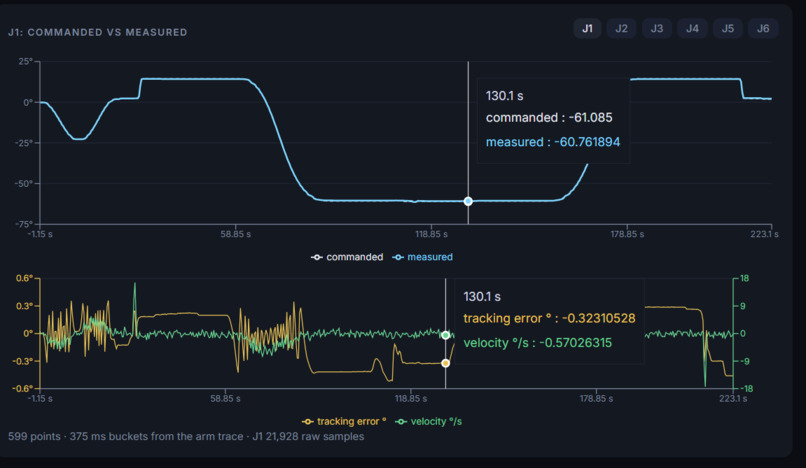
Photos and screenshots: Laminar team, from the Devpost submission.